In progress
Started September 2026
Open Duck Mini
A small open-source bipedal walking robot running on a Raspberry Pi Zero 2 W.
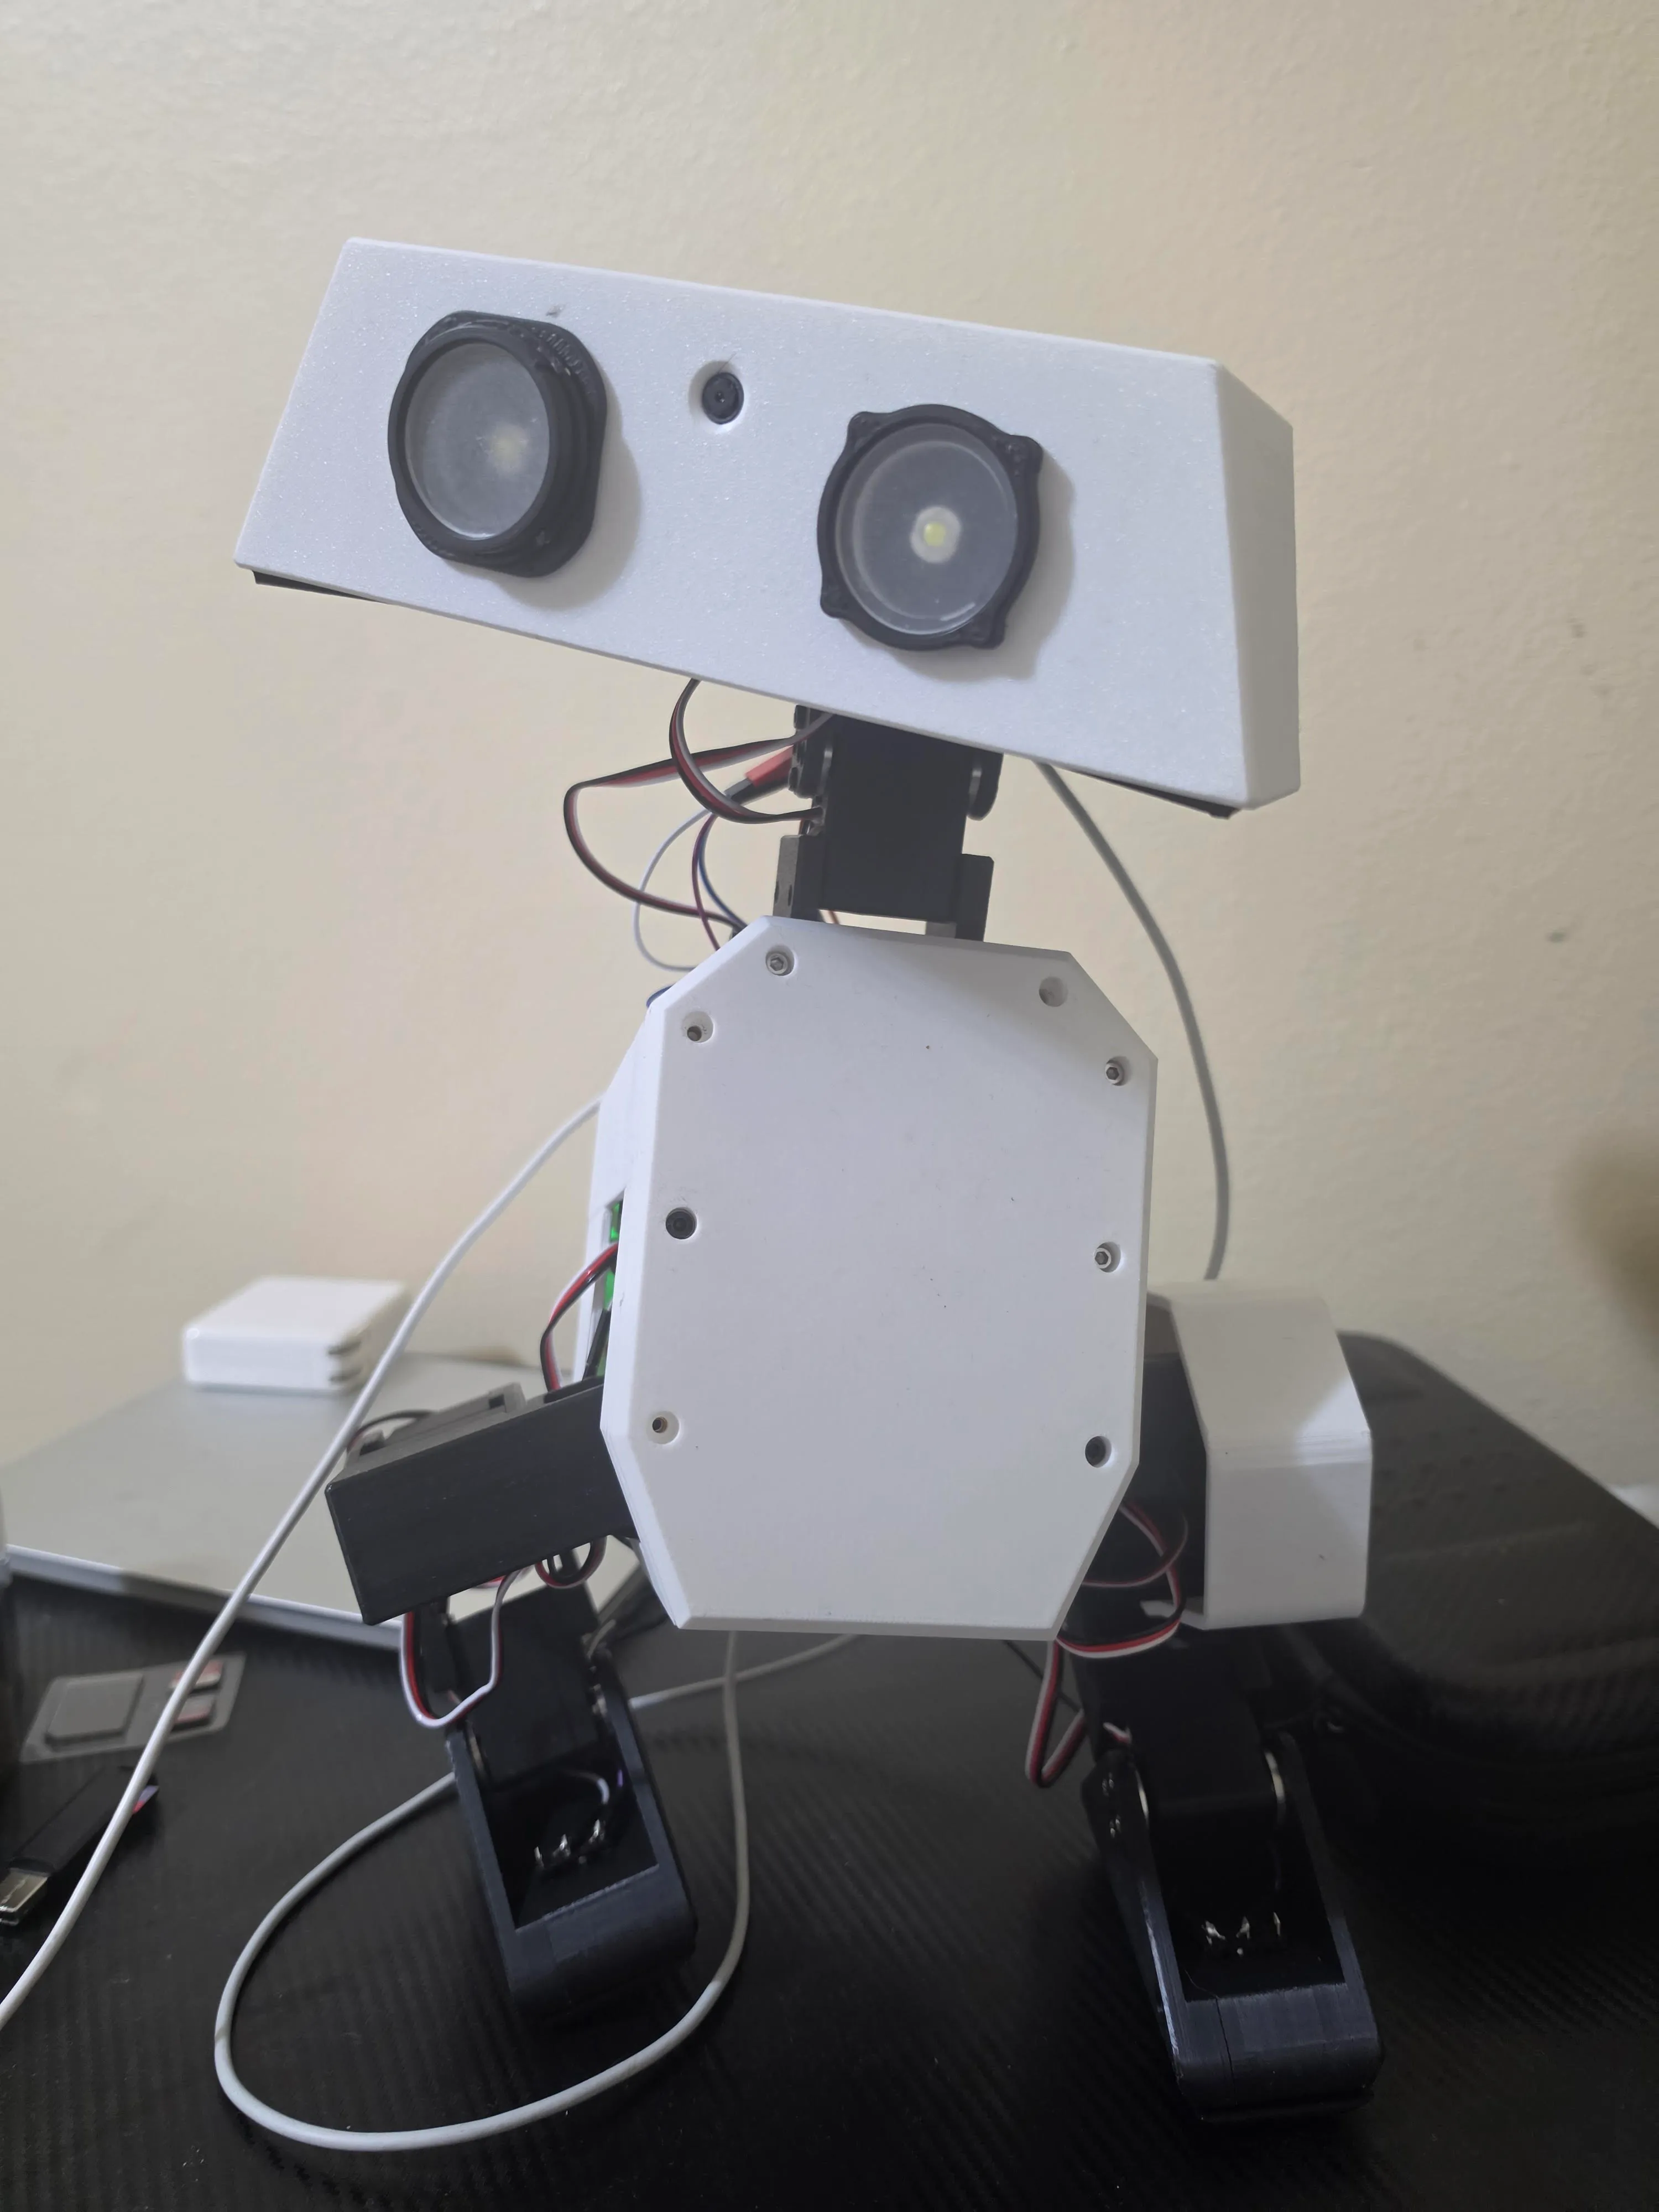
Overview
The Open Duck Mini is a miniature BDX Droid. I chose to build one to learn
Hardware
- Compute: Raspberry Pi Zero 2 W
- Actuators: TODO servo model and count
- Power: TODO battery and regulator
- Frame: TODO printed parts, material, print settings worth noting
A photo or two of the assembled robot goes well here. Drop images next to this file and reference them as .
Software
What runs on the Pi, how the control loop works, and anything you changed from the upstream project. Code blocks render with syntax highlighting:
# TODO: a short, interesting snippet from the project
def step(state):
    return policy(state)
Status
Where the build is right now, and what the last milestone was.
What’s next
- TODO: next milestone
- TODO: open problem you want to solve